freshcrate
Skin:/
Home > MCP Servers > ros-mcp-server

ros-mcp-server

Connect AI models like Claude & GPT with robots using MCP and ROS.

Why this rank:Strong adoptionRelease freshnessHealthy release cadence

Description

Connect AI models like Claude & GPT with robots using MCP and ROS.

README

ROS MCP Server 🧠⇄🤖

Static Badge Static Badge Static Badge Python pip Dev Container GitHub Repo starsGitHub last commit

ROS-MCP-Server connects large language models (such as Claude, GPT, and Gemini) to robots, enabling bidirectional communication with no changes to existing robot source code.

Why ROS-MCP?

  • No robot source code changes → just add the rosbridge node to your existing ROS setup.
  • True two-way communication → LLMs can both control robots and observe everything happening on the Robot.
  • Full context → publish & subscribe to topics, call services & actions, set parameters, read sensor data, and monitor robot state in real time.
  • Deep ROS understanding → guides the LLM to discover available topics, services, actions, and their types (including custom ones) — enabling it to use them with the right syntax without manual configuration.
  • Works with any MCP client → built on the open MCP standard, supporting Claude Code, Codex CLI, Gemini CLI, Claude Desktop, ChatGPT, Cursor, and more.
  • Works across ROS versions → compatible across ROS 2 (Jazzy, Humble, and others) and ROS 1 distros.

🎥 Examples in Action

🖥️ Example - Controlling the MOCA mobile manipulator in NVIDIA Isaac Sim
Commands are entered into Claude Desktop, which uses the MCP server to control the simulated robot.


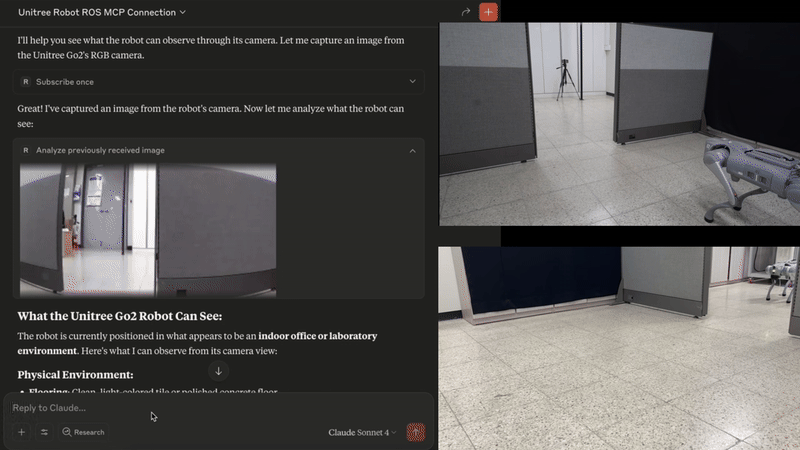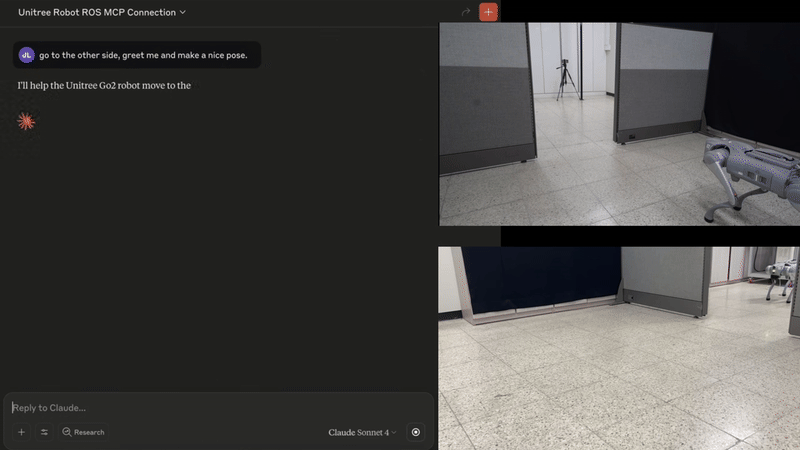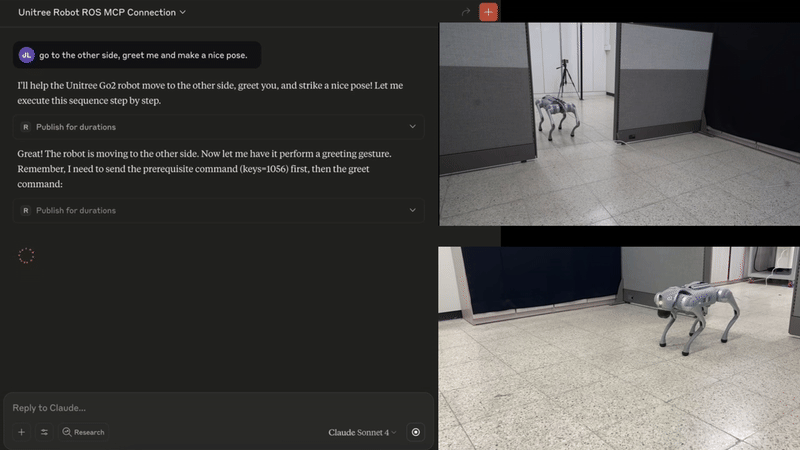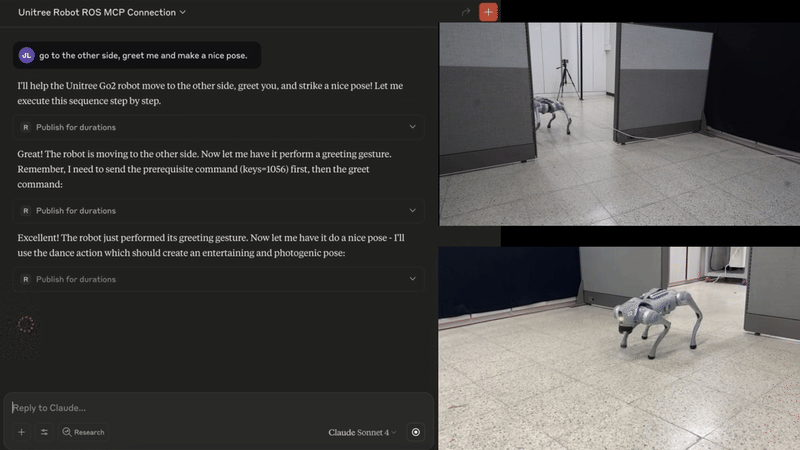
🐕 Example - Controlling Unitree Go2 with natural language (video)
The MCP server enables Claude to interpret images from the robot's cameras, and then command the robot based on human natural language commands.

🏭 Example - Debugging an industrial robot (Video)

  • Connecting to an industrial robot enables the LLM to browse all ROS topics and services to assess the robot state.
  • With no predefined context, the MCP server enables the LLM to query details about custom topic and service types and their syntax (00:28).
  • Using only natural language, the operator calls the custom services to test and debug the robot (01:42).

Testing and debugging an industrial robot


🛠 Getting Started

Follow the installation guide to get started.

ROS-MCP works with Claude Code, Codex CLI, Gemini CLI, Claude Desktop, ChatGPT, Cursor, or any MCP-compatible client.


📚 More Examples & Tutorials

Browse our examples to see the server in action.
We welcome community PRs with new examples and integrations!


🤝 Contributing

We love contributions of all kinds:

  • Bug fixes and documentation updates
  • New features (e.g., Action support, permissions)
  • Additional examples and tutorials

Check out the contributing guidelines and see issues tagged good first issue to get started.


📜 License

This project is licensed under the Apache License 2.0.

Release History

VersionChangesUrgencyDate
v3.1.2Fixed a versioning bug. Functionally identical to v3.1.1High9/23/2026
v3.1.1Bugfix of fastmcp version in pyproject.tomlHigh9/22/2026
v3.1.0## What's Changed * Release v3.1.0 by @stex2005 in https://github.com/robotmcp/ros-mcp-server/pull/342 **Full Changelog**: https://github.com/robotmcp/ros-mcp-server/compare/v3.0.1...v3.1.0High6/17/2026
v3.0.1Updates to CI Release notes at https://github.com/robotmcp/ros-mcp-server/pull/231 and https://github.com/robotmcp/ros-mcp-server/pull/232 This is a follow up to major release v3.0.0. Release notes at https://github.com/robotmcp/ros-mcp-server/pull/229Low1/29/2026
v3.0.0Feature release including major repository refactoring. Release notes at https://github.com/robotmcp/ros-mcp-server/pull/229Low1/29/2026
v2.2.1Updated instructions to utilize uvx Updated github actions for publishingLow11/6/2025
v.2.2.0Feature release https://github.com/robotmcp/ros-mcp-server/pull/184Low11/5/2025
v2.1.7Feature release https://github.com/robotmcp/ros-mcp-server/pull/176Low10/26/2025
v2.1.6Test release to confirm publish workflow to the MCP registryLow10/9/2025
v2.1.5Hotfix towards MCP registryLow10/9/2025
v2.1.4Release notes here https://github.com/robotmcp/ros-mcp-server/pull/134Low10/6/2025
v2.1.3Hotfix to solve installation bugsLow9/29/2025
v2.1.2Updated metadataLow9/17/2025
v2.1.1First release to be published on PyPiLow9/17/2025
v2.1.0Version for September 2025 Public LaunchLow9/11/2025

Dependencies & License Audit

Loading dependencies...

Similar Packages

streamdeck-mcpMCP server for Elgato Stream Deck control — set buttons, manage pages, wire actionsv0.3.0
pipulateLocal First AI SEO Software on Nix, FastHTML & HTMXmain@2026-10-25
voicemodeNatural (2-way) voice conversations with Claude Codev9.0.0
mcp-statcanA MCP server to use StatCAN datamain@2026-10-25
uk-due-diligence-mcpUK due diligence MCP server — Companies House, corporate research, compliance checksv1.4.3

More in MCP Servers

litellmPython SDK, Proxy Server (AI Gateway) to call 100+ LLM APIs in OpenAI (or native) format, with cost tracking, guardrails, loadbalancing and logging. [Bedrock, Azure, OpenAI, VertexAI, Cohere, Anthropi
ruflo🌊 The leading agent orchestration platform for Claude. Deploy intelligent multi-agent swarms, coordinate autonomous workflows, and build conversational AI systems. Features enterprise-grade archit
@claude-flow/cliRuflo CLI - Enterprise AI agent orchestration with 60+ specialized agents, swarm coordination, MCP server, self-learning hooks, and vector memory for Claude Code
claude-plugins-officialOfficial, Anthropic-managed directory of high quality Claude Code Plugins.